fn knight_attacks(sq: u8) -> u64 {
    let b = 1u64 << sq;
    ((b << 17) & !FILE_A) | ((b << 15) & !FILE_H)
  | ((b << 10) & !(FILE_A | FILE_B))
  | ((b >> 6) & !(FILE_A | FILE_B))
}

let idx = (occ & mask).wrapping_mul(MAGIC[sq]) >> SHIFT[sq];
let attacks = ROOK_TABLE[sq][idx as usize];

bool rb_push(ring_t *rb, uint8_t byte) {
    size_t next = (rb->head + 1) & (RB_SIZE - 1);
    if (next == rb->tail) return false;
    rb->buf[rb->head] = byte;
    rb->head = next;
    return true;
}
double error = target - encoder.getPosition();
integral += error * dt;
double derivative = (error - lastError) / dt;
double output = kP * error + kI * integral + kD * derivative;
motor.set(MathUtil.clamp(output, -1.0, 1.0));
lastError = error;

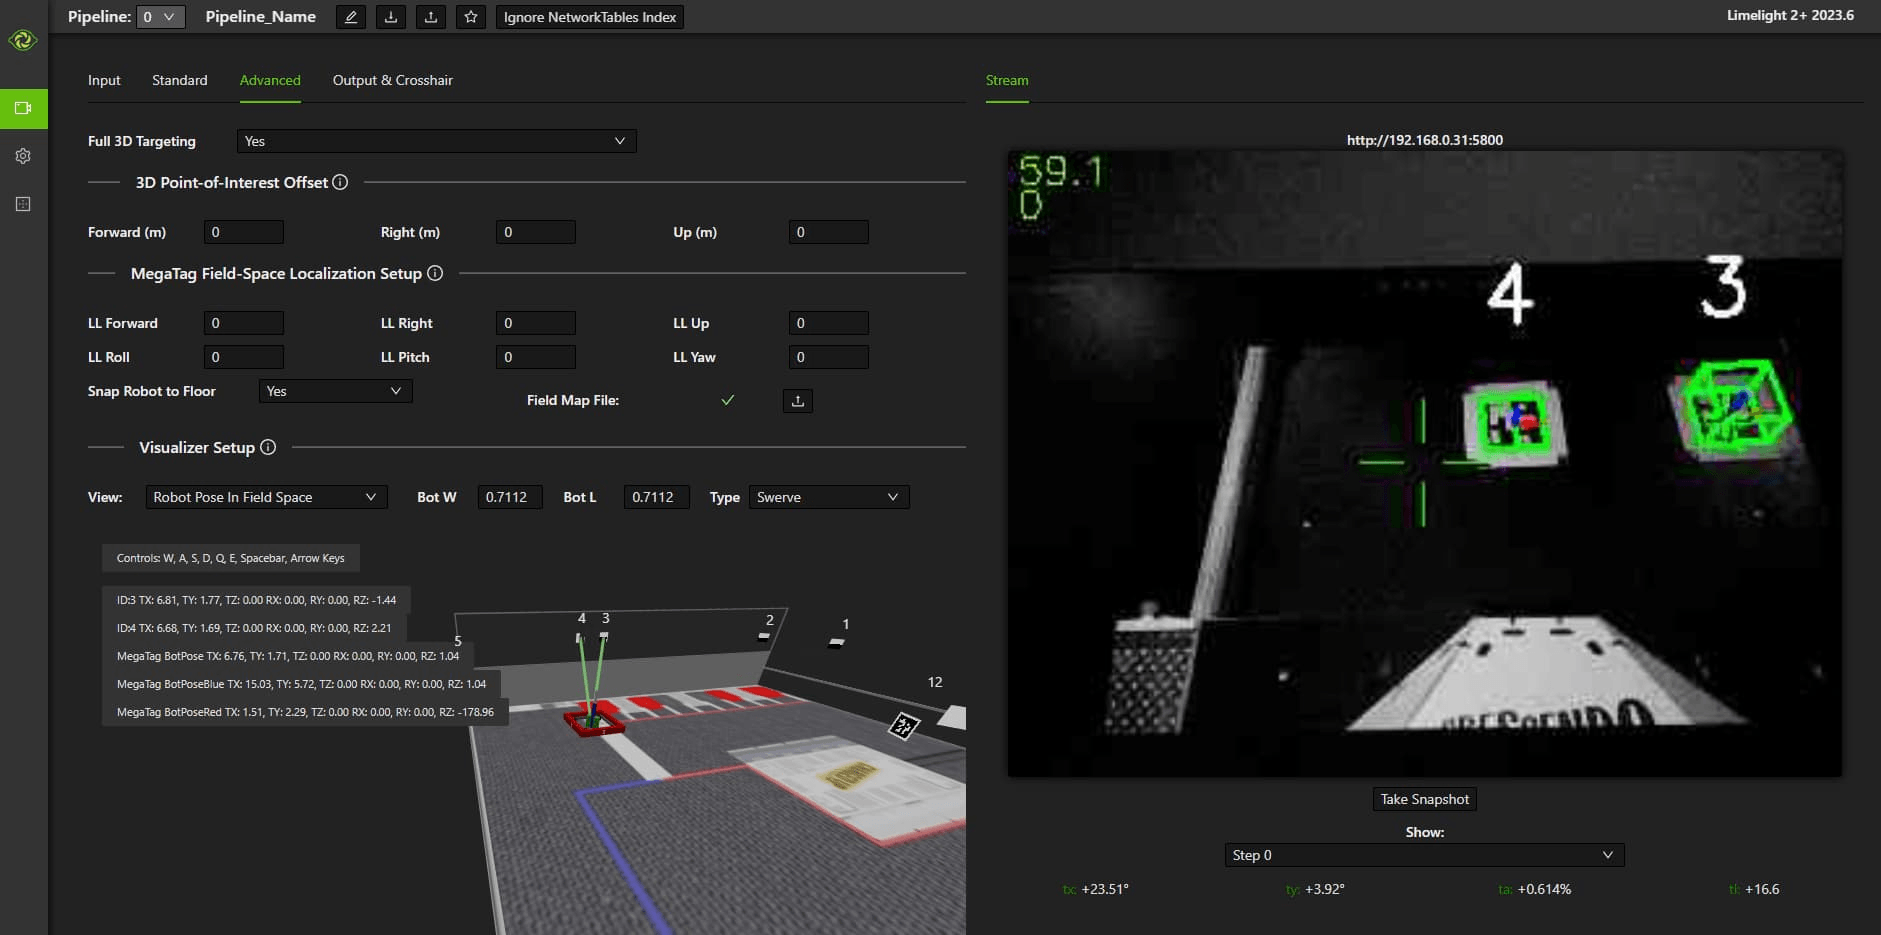
var pose = LimelightHelpers.getBotPoseEstimate_wpiBlue("limelight");
if (pose.tagCount >= 2) {
    odometry.addVisionMeasurement(pose.pose, pose.timestampSeconds);
}
AutoBuilder.followPath(PathPlannerPath.fromPathFile("Auto"));
fn negamax(pos: &mut Board, depth: u8,
           mut alpha: i32, beta: i32) -> i32 {
    if depth == 0 { return quiesce(pos, alpha, beta); }
    for mv in pos.legal_moves() {
        pos.make(mv);
        let score = -negamax(pos, depth - 1, -beta, -alpha);
        pos.unmake(mv);
        if score >= beta { return beta; }
        alpha = alpha.max(score);
    }
    alpha
}

self.onmessage = ({ data }) => {
  engine.send_command(`position startpos moves ${data.history}`);
  const best = engine.send_command("go wtime 300000");
  postMessage({ type: "bestmove", move: best });
};
bool rb_push(ring_t *rb, uint8_t byte) {
    size_t next = (rb->head + 1) & (RB_SIZE - 1);
    if (next == rb->tail) return false;
    rb->buf[rb->head] = byte;
    rb->head = next;
    return true;
}

double error = target - encoder.getPosition();
integral += error * dt;
double derivative = (error - lastError) / dt;
double output = kP * error + kI * integral + kD * derivative;
motor.set(MathUtil.clamp(output, -1.0, 1.0));
lastError = error;
Computer Science @ UT Austin
CarlosCantu.
UT Austin Computer Science student engineering performant, reliable software — from low-level algorithms to scalable systems.